Login

Inside Ukraine’s First Combat Deployment Of Robotic Amphibious Vehicles
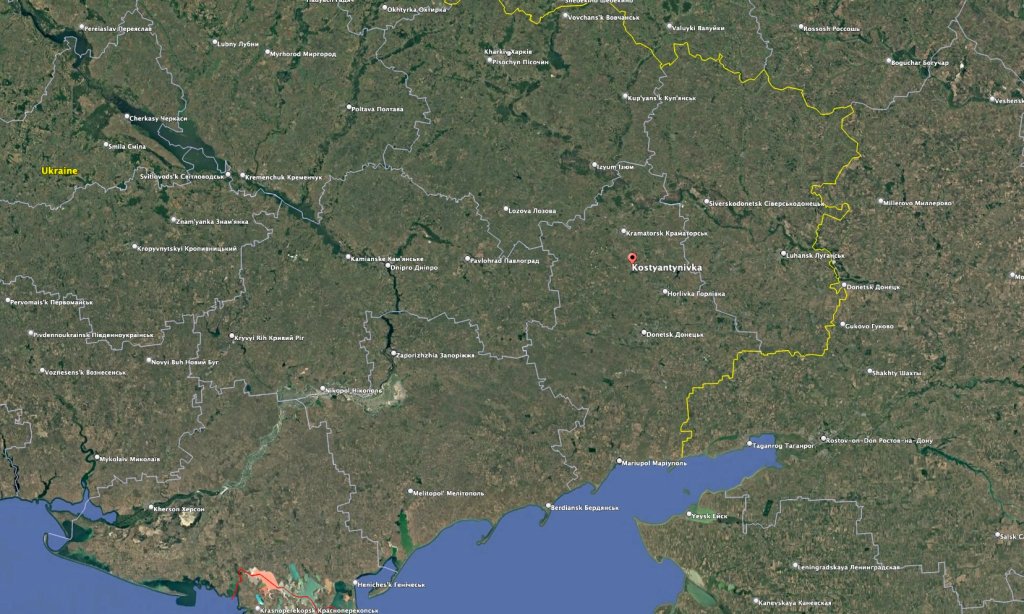
Taking a break from fighting Russians in the Kostiantynivka sector of the eastern Donetsk region, the commander of a Ukrainian uncrewed ground vehicle (UGV) unit spoke with us about innovations in the use of these systems. One was the first deployment of a UGV specifically designed for amphibious operations to deliver supplies to frontline troops in areas impeded by water obstacles. Large areas of the front line are bisected by rivers and wetlands, and the country has many other small waterways and marsh areas. As we have frequently reported, the use of UGVs by both Ukraine and Russia has exploded as the ubiquity of aerial attack drones makes it far too dangerous for human battlefield movements.
In an exclusive interview with TWZ, the commander of the 93rd Separate Mechanized Brigade’s “Alter Ego” UGV unit, who goes by the call sign “Electric,” offered us unique insights into the challenges of developing amphibious UGVs and how they were deployed.
In the first of two parts, Electric talks about why Alter Ego developed amphibious UGVs – including modifying a Triton variant for this – and how the unit made them work. The second part features his insights into using heavy ‘bomber drones’ to drop UGVs behind enemy lines for kamikaze raids. In addition, a representative of Brave1, Ukraine’s weapons technology accelerator, spoke about developing these systems at scale.
Some of the questions and answers have been slightly edited for clarity.
Q: How did the need for amphibious UGVs for logistics operations first come up?
A: We had this idea for a long time, but recently one of the units of the Armed Forces asked for our help to solve this problem, so that the UGV could overcome water obstacles.
There was a crucial need for this kind of means at certain parts of the front, but the units that are located there didn’t have the capacity by themselves to solve this task. So our battalion was asked to solve this problem because we are one of the most experienced units in terms of UGVs.
A first-ever logistics mission on an amphibious UGV: the robot covered 40 kilometers across land and water.
— BRAVE1 (@BRAVE1ua) September 29, 2026
Operators of the "Alter Ego" unit (93rd Brigade) deployed the robotic system across mixed terrain. Facing water obstacles, the UGV seamlessly switched to swimming mode to… pic.twitter.com/rH8waq04a4
Q: How long did it take to design and test the amphibious UGV, and what went into that process?
A: The whole process from development to battle deployment took less than three months.
Q: What did you have to do to make this work?
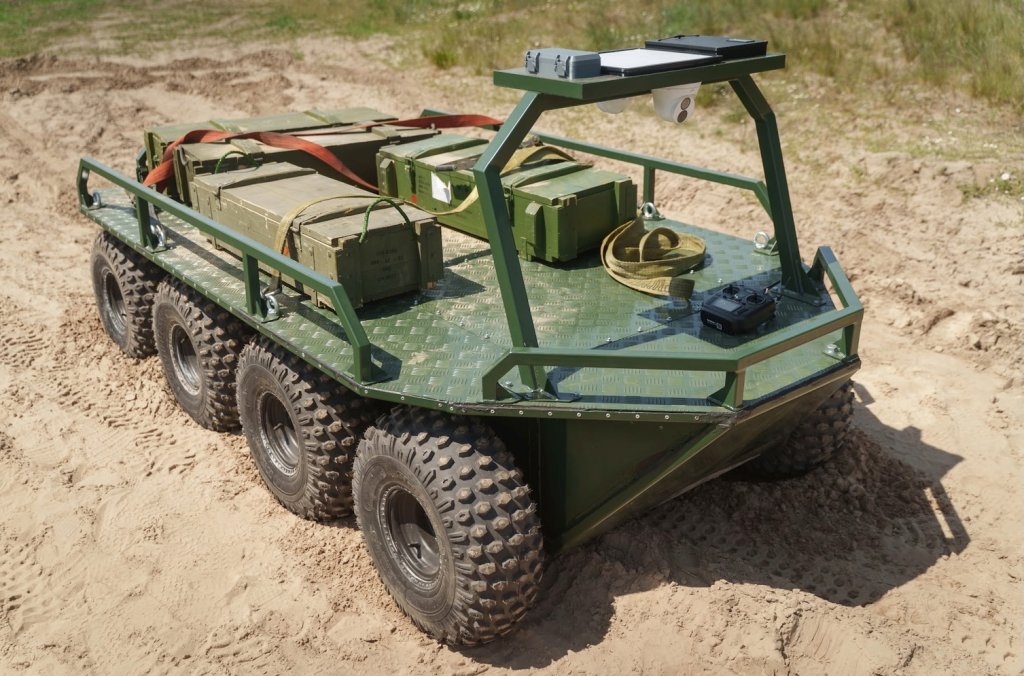
A: First of all, we looked at amphibious solutions that were on the market, not only in Ukraine, but in the world, and we took two separate approaches. One was taking one of the main UGVs that our unit is using on the ground, and we made it amphibious. And the other approach was that we took one of the solutions that was on the market that already had amphibious capabilities, and we solved several disadvantages that it had. And at the moment, we are using both.
Q: What did you have to do to make the UGV amphibious, and then what were some of the obstacles that had to be overcome to get this operational?
A: First of all, we have to explain that there are different solutions on the market that kind of work on the testing ground — like they can swim, they can drive on the ground, and in the vision of the manufacturer, they are working. But the fact is that these solutions are not ready for the reality on the front line, which is often very different from what is on the testing ground.
And the second point is that the unit has its own workshops where people work near the front line, and the experts, the engineers that work there, they have a very high level of competence to evaluate different solutions and select the one that has potential. And that’s what’s completely different between this unit and everyone else, like manufacturers and others who are working on these solutions, because they don’t understand what’s needed on the battlefield.
Q: So what did you have to change to make it work?
A: Regarding the amphibious one, basically the unit changed almost everything that that UGV had, starting from electronics, the software, the waterproofing, the communications – we basically changed everything. Regarding the one that we already used on the ground, we basically tried to retain what was allowing it to be an effective UGV on the ground, and we added waterproofing and specific mechanics, so that it can work in the water environment.
Q: You mentioned communications. What kind of communications did you add?
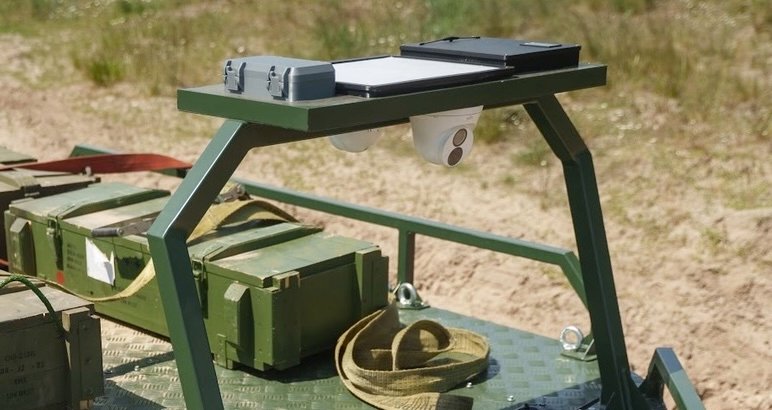
A: The communication means that was installed on the UGV by the manufacturer was not sufficient at all. Basically, it didn’t have enough quality for the battlefield situation. It was not working. But we already have our own communications that we were working on, and we have a lot of experience because we have been working for a long time in this UGV area. So we basically helped to install a sufficient level of communications on this UGV.
Q: So how does the amphibious UGV communicate with the controller? Does it use Starlink or some other satellite communications system for navigation?
A: This is satellite navigation, but not only. Satellite navigation is a part of this communication system.
Q: What are the other parts?
A: It’s better not to talk in detail about the other part of the communication system.
Q: There were probably a lot of different missions that could have been used for this first amphibious UGV logistics delivery. Why was this particular mission chosen?
A: The Alter Ego unit has so much experience in terms of UGVs, and not just experience of using UGVs, but the experience of being the first in the world. We had one of the first evacuation missions, we had one of the first strike missions using UGVs, the paratrooper UGV, and now the amphibious UGV. So basically, we have the systems to make it work for the first time when nobody knows how to conduct this mission.
Q: No, I mean why did this particular mission get chosen to be the first one?
A: There are certain places on the front line where we have water obstacles that prevent logistics from being done by UGV. At the moment, UGVs are carrying hundreds of tons of logistics, probably the most compared to any other means on the front line, but before this, these water obstacles would prevent UGVs from providing logistics for those parts of the front, and that need can’t be fully satisfied by UAVs or other means. That’s why we did this mission with the amphibious UGV, and now our task here is to scale this technology and provide this logistics system for other similar parts of the front where there are water obstacles.
Q: Tell me about where and when this mission took place and what it was like to watch it unfold.
A: So unfortunately, we can’t provide information about when and where this operation took place. But regarding how it went and what we felt, this was another big challenge, because this is something that wasn’t done before, and nobody thought this is real. So this was quite difficult, and to tell the truth, the mission didn’t succeed on the first try, actually, and it required a lot of effort in terms of planning, preparing, engineering, and basically it required 100% effort from everyone involved in that mission.
Q: How many times did it fail before, and what went wrong?
A: We had one failed attempt. The reason for failure was a certain technical problem. After that, we analyzed what went wrong, and we worked on solving those issues. Basically, it’s something that nobody had tried to do, it’s kind of hard to know what can go wrong before you actually try it. So the best way to find a solution like that is to try and then iterate on that attempt and make it better and better and better.
Also, I would like to add that although this was the first successful mission regarding an amphibious UGV, it’s not that there was no work on that before that. We were actively talking to and collecting the experience of everyone who was working on these kinds of missions before, and that was also a reason why this mission succeeded.
Q: How far did the amphibious UGV go for this mission?
A: So the UGV went 40 kilometers one way, and then it returned. So probably around 70 kilometers in total, and it carried food and other supplies.
Q: Did this UGV come under Russian fire on this mission?
A: Yes, and it survived.
Q: How does the UGV switch from water to land operations?
A: So the UGV has two separate control systems, one for water and one for land, and basically it switches to the one that is required at the moment. That’s how it can operate in both environments.
Q: Is that autonomous, or is that something that the controller at the base has to do as they watch the UGV on its mission?
A: At the moment, the operator fully controls the UGV manually. And basically, before, the operators of UGVs only knew how to move them on land, but now they also had to learn how to move them in the water. So not only was the technology itself developed, but we also had to prepare the operator and come up with tactics for this UGV.
Q: Did you use AI on this mission in any way, and if so, how?
A: We didn’t use AI.
Q: Have there been other missions using amphibious UGVs?
A: Yes.
Q: Can you say how many and what was delivered?
A: No.
Q: Is this designed only for logistics missions, or will it be used in the future for strike missions, either as a one-way attack system or as a platform for machine guns or other weapons?
A: We can use it in different ways in the future.
Q: Mud season is fast approaching, when much maneuvering becomes impossible or severely degraded because of how difficult it is to move in the thick, oozing slop. Will your amphibious UGVs work in the mud?
A: I think it can operate in the mud in the same way it operates in the water.
In the next segment of our interview, Electric talks about using bomber drones to deliver UGVs behind the lines, and a Brave1 representative talks about how the organization is working to develop these systems at scale for wider use.
Contact the author: howard@twz.com
The post Inside Ukraine’s First Combat Deployment Of Robotic Amphibious Vehicles appeared first on TWZ.